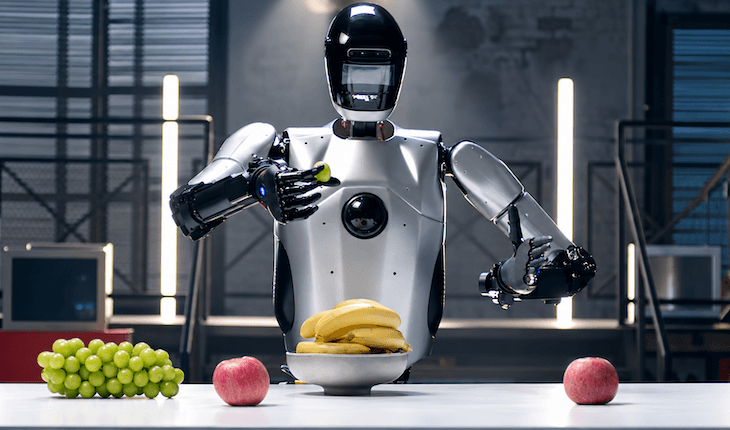
Qinglong is a full-size open-source humanoid robot featuring a 1.85-meter body height, 43 biomimetic degrees of freedom, multi-sensory perception, and advanced motion control capabilities. Its lower body integrates SEMOTOR’s high torque-density axial flux joint motors, providing stable movement and reliable performance for embodied intelligence research and robot development.
SEMOTOR Advantages
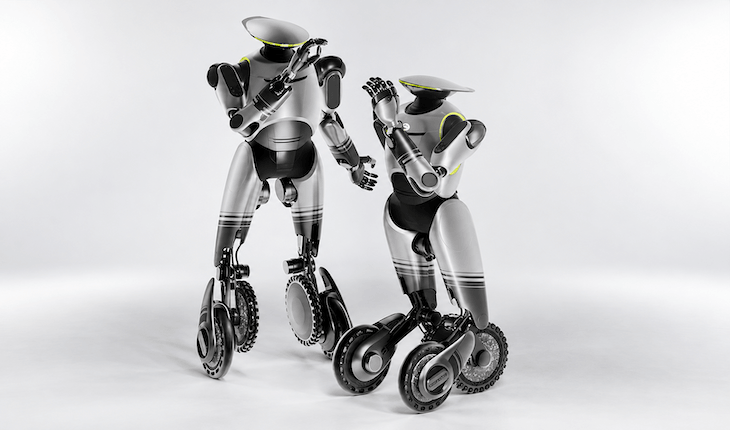
GoMate is GAC’s third-generation wheeled-legged embodied humanoid robot, featuring an innovative variable wheel-leg architecture that enables both humanoid standing and stable four-wheel mobility. Its lower-body and waist joints integrate SEMOTOR’s high power-density axial flux integrated joint modules, delivering strong mobility, lower energy consumption, and up to 6 hours of endurance for applications including inspection, public services, and healthcare.
SEMOTOR Advantages
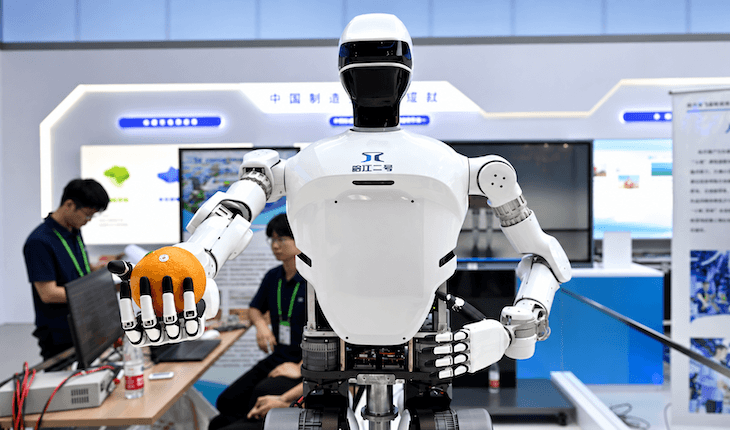
Qijiang No.2 is a full-size biped humanoid robot independently developed by JAC, featuring a 1.8-meter body height and 38 degrees of freedom. With an optimized forward-bending leg structure, multi-sensor perception system, and embodied intelligence control technology, it achieves stable walking on unstructured terrain and precise manipulation. Its lower body integrates SEMOTOR’s high torque-density axial flux joint modules, providing reliable performance for industrial, healthcare, and public service applications.
SEMOTOR Advantages
SEMOTOR is a leading provider of axial-flux motor technology and electric drive solutions, delivering compact, efficient, and high-performance power systems for advanced intelligent equipment.
17A06.07, Building 3, Phoenix Plaza, Phoenix Street, Guangming District, Shenzhen, China
© 2026 SEMOTOR. All Rights Reserved.
Designed by AdmarV